Zhongtao (Tony) Guan
Hi, I’m Tony, a PhD student in the Department of Electrical Engineering and Computer Science (EECS) at MIT, advised by Prof. Kevin Chen. I received (President’s List) my bachelor’s degree in Electronic Information Engineering from ShanghaiTech University, advised by Prof. Yu Liu, and Jiahao Chen.
My research interests are autonomous systems co-design, aerial robotics, microrobotics, and hybrid locomotion. I am interested in developing an execution and decision-making system for micro robots that can achieve athletic abilities, robustness, and intelligence in the real world through the conjunction of perception, control, and mechatronic design.
selected publications
-
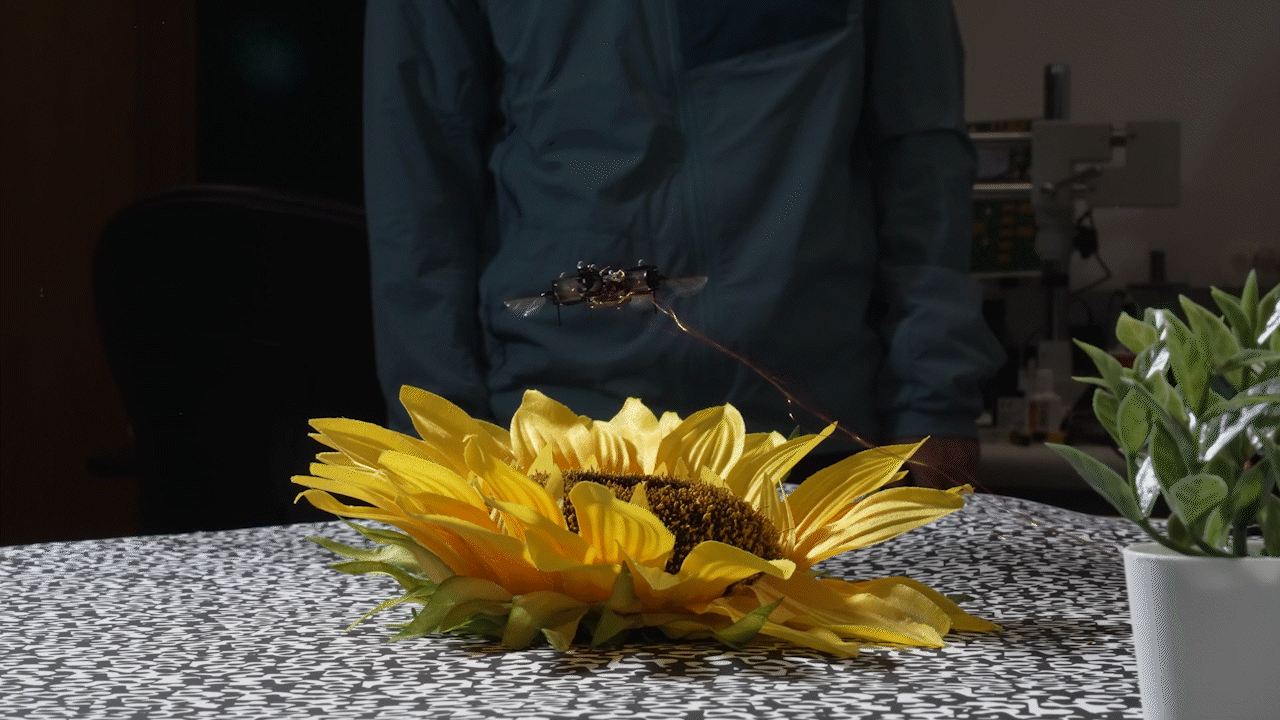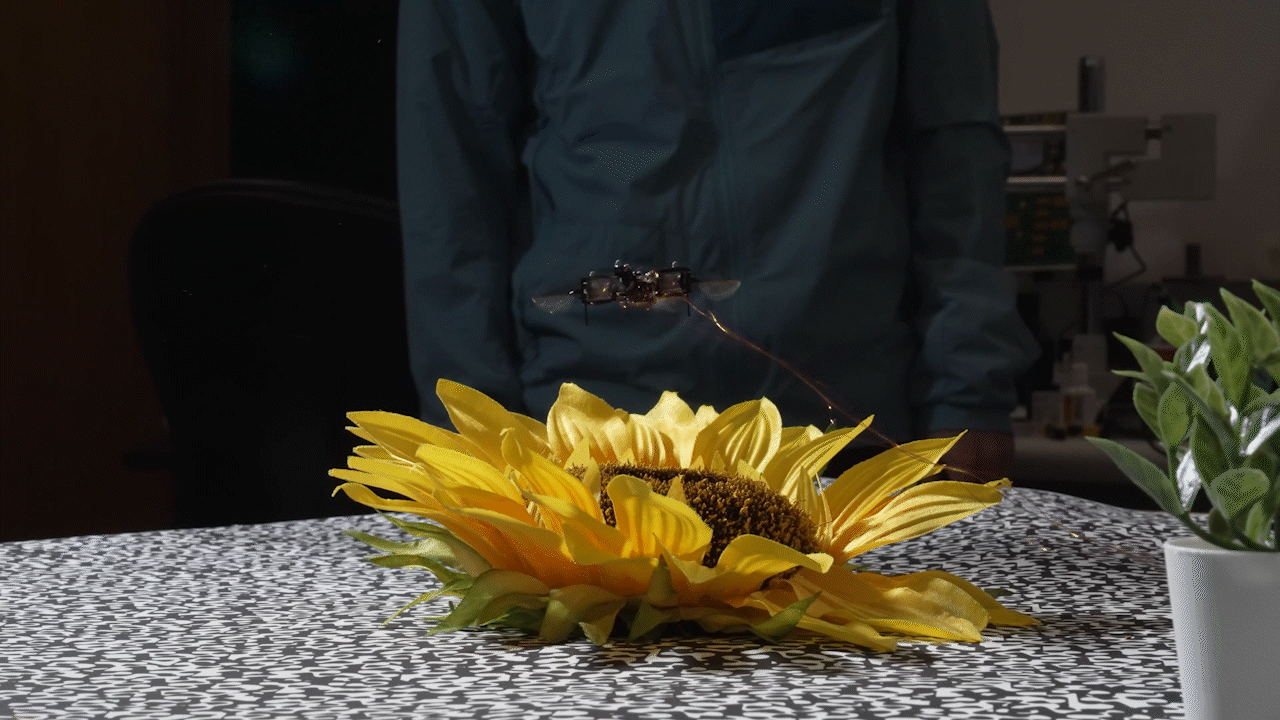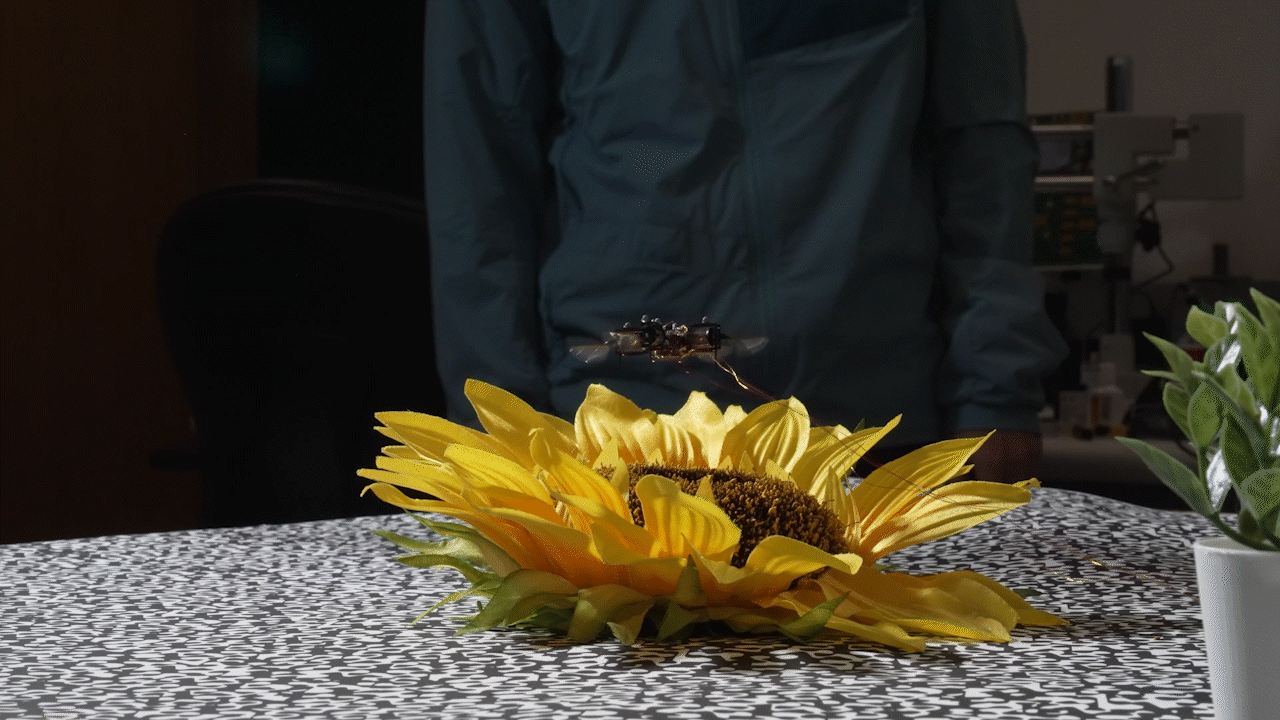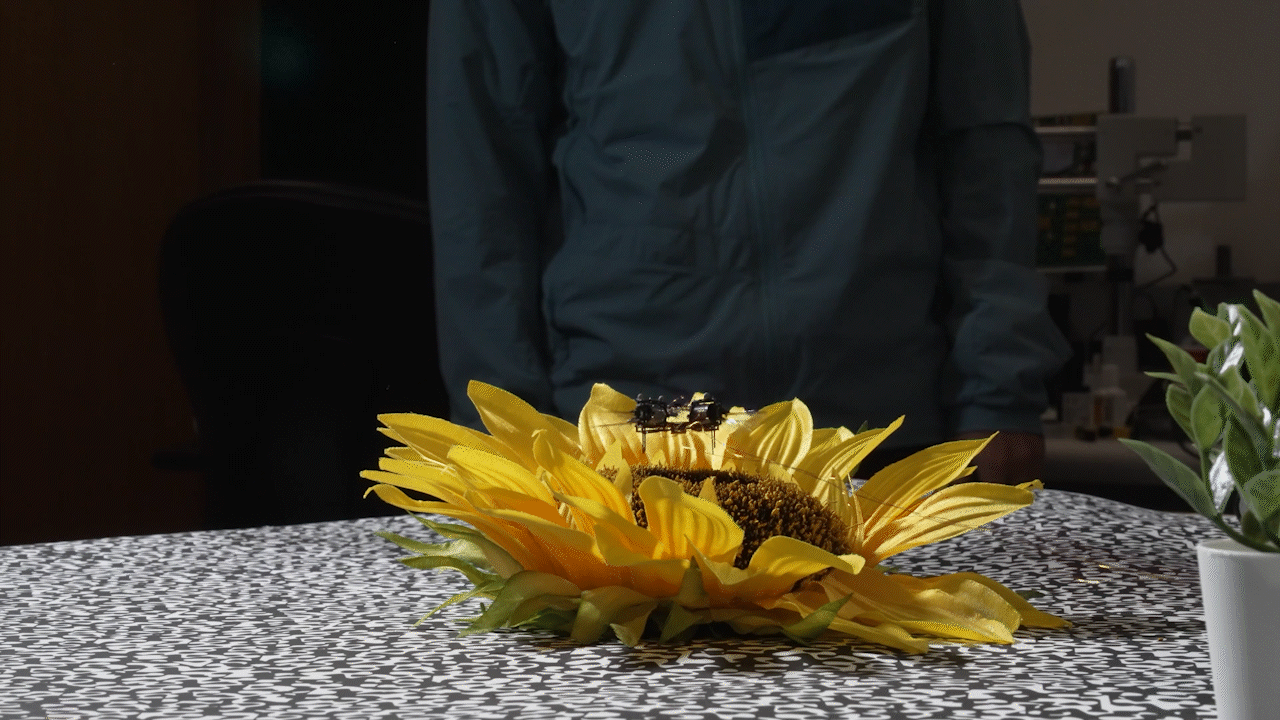 Controlled Flight of an Insect-Scale Flapping-Wing Robot via Integrated Onboard Sensing and ComputationarXiv preprint arXiv:2602.08328, 2026Pre-accept at Science Robotics
-
 Hybrid locomotion at the insect scale: Combined flying and jumping for enhanced efficiency and versatilityScience Advances, 2025
-


news
| Sep 01, 2026 | Awarded the MathWorks Fellowship (2026–2027) at MIT. |
|---|---|
| Feb 01, 2026 | Our paper on controlled flight of an insect-scale flapping-wing robot with integrated onboard sensing and computation is pre-accepted at Science Robotics. Preprint on arXiv. |
| Jun 01, 2025 | Graduated from ShanghaiTech University with a B.Eng. in Electronic Information Engineering with the honor of President’s List). |
| Apr 09, 2025 | Our work on hybrid locomotion at the insect scale is published in Science Advances, and was covered by MIT News, IEEE Spectrum, Tech Briefs, and Veritasium. |